 ← Back to Blog
The Future of AI Robotics: Humanoids, Machine Bodies, and Biology in the Loop
A futuristic briefing on versus humanoid robots: why specialized machines still win near-term, how and research changes the long game, and what software teams should build now.
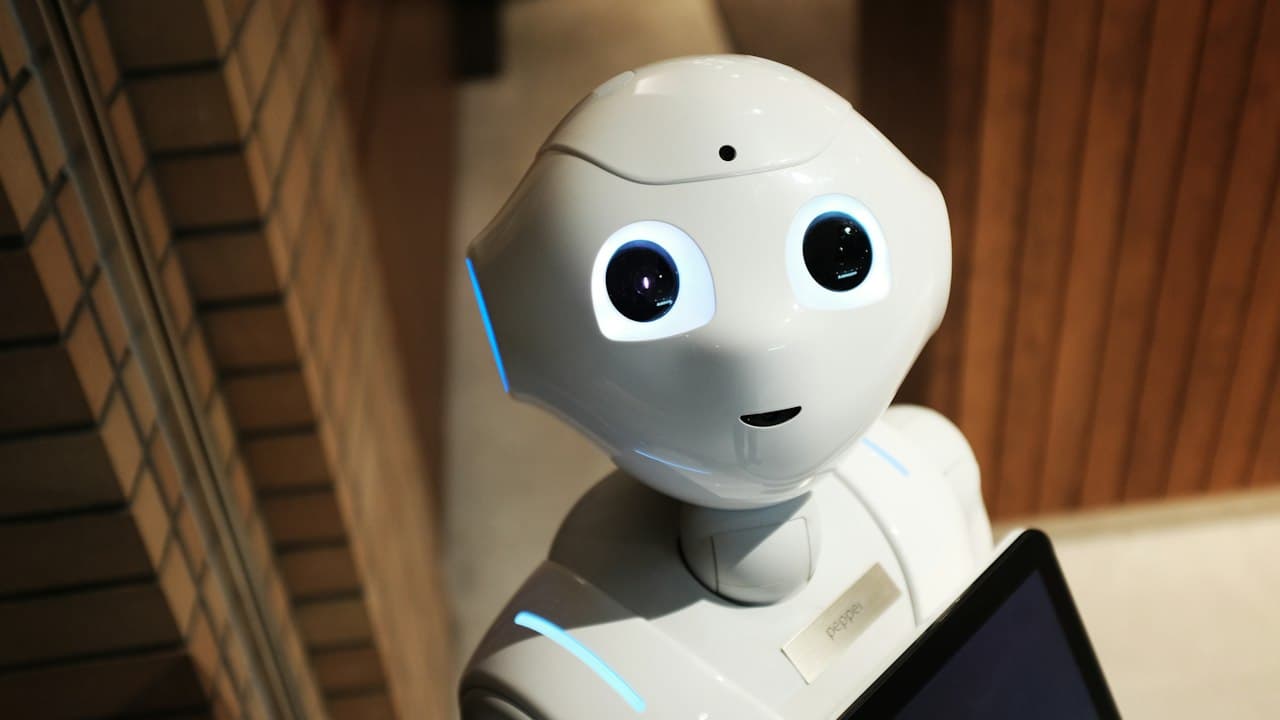
AI robotics is leaving the chat window. The next race is who gets a body, and whether that body should look human at all.
Listen to this briefing
Speech is not supported in this browser. Try Chrome or Edge.
Large models plan in language. Robots act in physics. The public story fixates on that walk into warehouses and homes. The engineering story of is broader: arms, mobile bases, drones, soft grippers, and research platforms that borrow tricks from biology.
Human form helps when the world was built for people, doors, shelves, tools. It is also expensive in balance, energy, and reliability. and other purpose-built machines often deliver ROI years earlier than general-purpose torsos.
Biology enters two ways: design (soft actuators, insect-like locomotion, sensing) and research (living materials or neural interfaces). That is related to, but distinct from, CL1-style biological computers. Here the question is : how intelligence couples to a body.
win the near term
, AMRs, and inspection drones dominate real deployments. They optimize for a narrow task: weld, pick, scan, haul. Safety cages, fixed routes, and known SKUs make reliability achievable.
If your KPI is cost per pick or defects escaped, a humanoid is optional. A sharp stack and a boring control loop usually beat a general-purpose torso.
chase general-purpose labor
aim to reuse human spaces and tools without redesigning the building. Progress in locomotion, dexterous hands, and models is real, and still uneven outside lab demos.
Expect early wins in controlled campuses and structured logistics before open-world homes. Treat viral videos as research previews, not purchase orders.
How biology works with
design copies principles: compliance instead of rigid metal, event-based sensing instead of fixed-frame cameras, morphological computation where the body itself filters noise. and hardware sit in this lane.
research goes further, interfaces to living tissue, muscle-like actuators, or wetware experiments. Most companies will not grow neurons for warehouse bots. They will adopt sensors, materials, and control ideas that biology already optimized.
Digitally, the stack still looks familiar: multimodal , a planner or agent, low-level control, and simulation. Compile Vision’s lane is that software brain (vision pipelines, operator UIs, , and RAG over robotics docs), while hardware partners own motors and frames.
What to build while the bodies catch up
Ship and workflow software that works on today’s arms and cameras. Add evaluation, safety interlocks, and human takeover. When humanoid platforms mature, your orchestration layer should already speak a clean .
Read our CL1 and analog computing briefings for the research horizon; use this piece for strategy. The future is not only , it is a zoo of machine bodies, some quietly borrowed from biology.
Key takeaways
are the viral path; are the ROI path today.
Biology contributes inspiration now and hybrid research later.
Embodied AI still needs , planning, control, and safety software.
Design skill APIs so new bodies can plug into existing workflows.
Compile Vision builds the digital brain beside whatever body you deploy.
Robot body strategies (and how they differ)
Choose embodiment for the job, not for the demo reel.
| Approach | How it works | Best for | Differs by |
|---|---|---|---|
| Specialized industrial | Fixed or rail-mounted arms/AMRs optimized for one workflow. | Factories, DCs, inspection routes with clear ROI. | Highest reliability today; least “general intelligence.” |
| Humanoid generalists | Bipedal platforms aiming to use human tools and spaces. | Future flexible labor in human-centric buildings. | Hardest mechanics; still maturing for open worlds. |
| Bio-inspired soft / morphing | Compliant materials, unusual gaits, safer human contact. | Care, food, fragile-object handling, research. | Trades peak force for safety and adaptability. |
| Bio-hybrid research | Living tissue or neural interfaces coupled to machines. | Labs exploring wetware + embodiment frontiers. | Not a warehouse SKU, adjacent software still matters. |
Tools & stack options
Practical pieces teams use to prototype and ship.
| Tool | Role |
|---|---|
| ROS 2 / Nav2 | Robot middleware, navigation, and skills |
| Isaac Sim / Gazebo | Simulation and sim-to-real testing |
| Vision-language-action models | Map language goals to motor skills |
| OpenCV / detectors / depth cameras | Perception stack on the body |
| LangGraph / agent runtimes | High-level task planning with tools |
| Digital twin dashboards | Fleet status, logs, and operator takeover |
| Literature RAG | Search papers and manuals while designing skills |
| Compile Vision operator UI | Human supervision and audit trails |
What you can build
- Warehouse pick cells with vision + arm skills and human takeover
- Inspection drones with multimodal anomaly reports
- Humanoid pilots on closed campuses with skill APIs
- Soft-gripper cells for fragile goods
- Fleet dashboards that treat robots like production services
- Research portals that explain bio-inspired options to executives
Architecture & diagrams
Embodied AI stack (digital + physical)
Software layers Compile Vision focuses on, with a research branch for bio-inspired paths.
Near-term vs long-term embodiment bets
Where to invest product dollars versus research attention.
Essential reading
References & further reading
Sources matter as much as the briefing itself. Start with the primary reference, then dig into the supporting links.
Wetware computing vs embodied robotics, related frontiers, different products.
- 2Compile Vision: Analog computers explained
Energy-efficient and neuromorphic hardware context for future robot brains.
- 3ROS 2 documentation
Industry-standard robot software framework.
- 4NVIDIA Isaac
Simulation and robotics AI tooling used in many modern stacks.
Learning / build steps
- 1
Pick the job
Task, environment, safety class
- 2
Choose the body
Specialized vs humanoid vs mobile
- 3
Wire perception
Vision, force, localization
- 4
Plan + control
Skills, agents, low-level loops
- 5
Operate + learn
UI, logs, sim, human takeover
Building the digital side of robotics?
Compile Vision ships perception pipelines, robot/agent operator UIs, simulation dashboards, and knowledge systems around your hardware partners. Tell us the job and the body, you will get a concrete software plan.
Contact Compile VisionRead next
Continue with related Compile Vision research briefings and builder guides.

11 min read
CL1 Explained: Biological Computing with Real Neurons
A detailed briefing on Cortical Labs CL1: how silicon meets living neurons, what biOS and Cortical Cloud enable, research possibilities, software angles for builders, and how Compile Vision can help teams explore adjacent AI products.

13 min read
Analog Computers Explained: From Op-Amps to In-Memory AI Hardware
A research briefing on analog computing: how continuous signals differ from digital bits, why analog and neuromorphic hardware are returning for AI efficiency, memristors and in-memory compute, and what software teams should build today.

14 min read
AI Agents Explained: From Chatbots to Autonomous Workflows
A newspaper-style briefing on AI agents in 2026: agent types compared (ReAct, tool-calling, multi-agent, swarm, voice, coding), tools, build paths, and how Compile Vision can ship one for you.